ProblemRemote robotic controls can be unintuitive and disconnect a user’s natural movement from the machine.
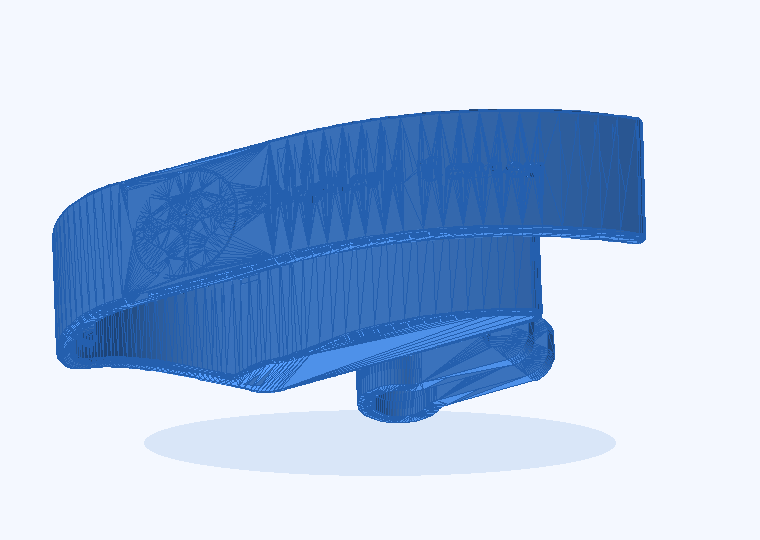
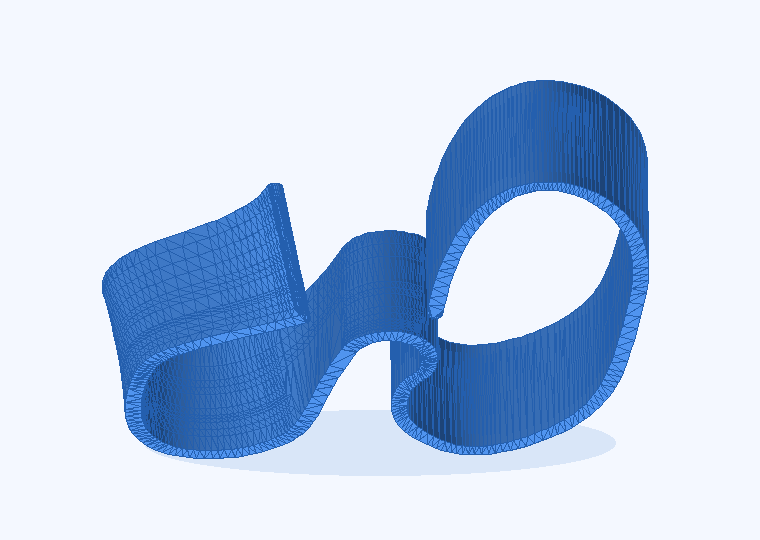
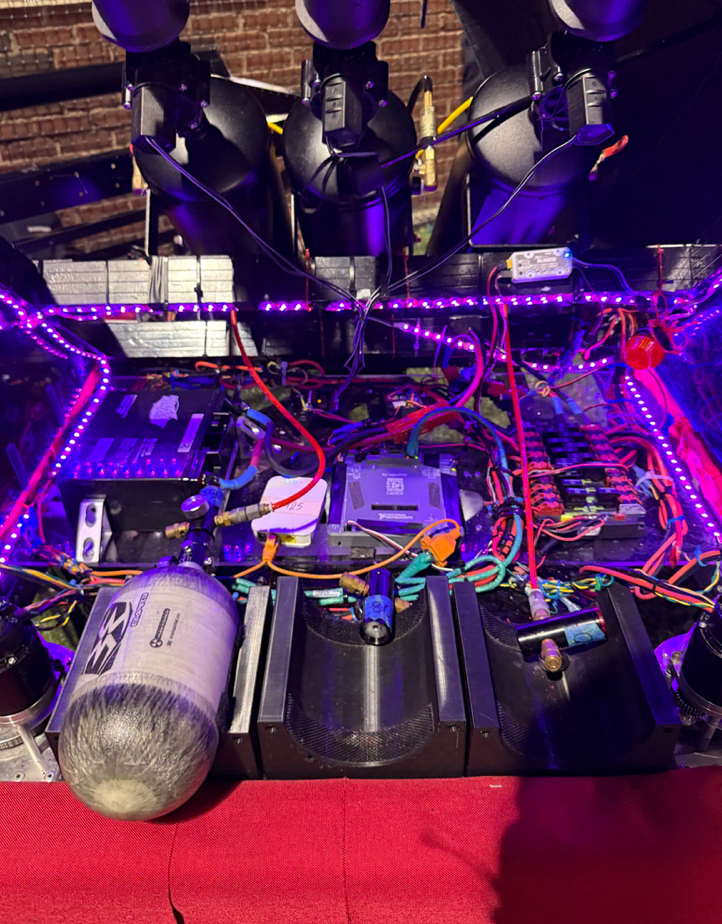
MethodologyMap hand gestures to robotic motion, integrate wearable sensors and Bluetooth communication, then iterate across the electronics, mechanical assembly, and response behavior.
SolutionA wearable glove prototype that translates human hand movement into commands for a robotic hand.
OutcomeA working exploration of embodied control, wireless communication, and accessible human-machine interaction.
Bluetooth · sensors · electronics · CAD · robotic actuation
 let’s connect!
 Additional featureAspen Institute